Holybro Pixhawk 6X Standard Set with M10 GPS
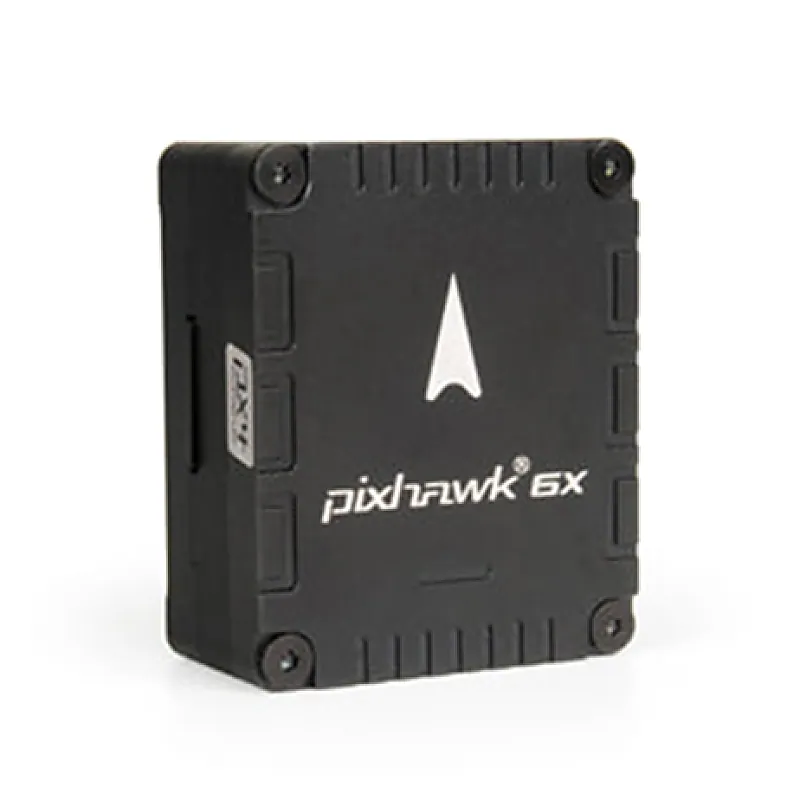
Holybro Pixhawk 6X Standard Set with M10 GPS
Advanced modular flight controller features triple redundancy for maximum reliability, integrating three ICM-45686 IMU sensors with BalancedGyro technology and two barometer sensors for enhanced precision. Powered by a high-performance STM32H753 processor with a clock speed of up to 480 MHz, it ensu
+ 18% GST (added at checkout)
In stock — 1 units ready
- Triple Redundancy: Three ICM-45686 IMU sensors and two barometer sensors for enhanced precision and reliability.
- High-Performance Processor: STM32H753 processor with a clock speed up to 480 MHz ensures robust processing capabilities.
- Modular Design: Separates IMU, FMU, and Base system with Pixhawk Autopilot Bus connectors for flexible integration.
- Isolated Sensor Domains: Completely isolated sensor domains with separate buses and power control for maximum reliability.
- Advanced Vibration Isolation: Durable vibration isolation material with higher spectrum resonance frequency for optimal stability.
- FMU Processor: STM32H753 32 Bit Arm Cortex-M7, 480MHz, 2MB flash memory, 1MB RAM
- IO Processor: STM32F103 32 Bit Arm Cortex-M3, 72MHz, 64KB SRAM
- Accel/Gyro: 3x ICM-45686 (with BalancedGyro Technology)
- Barometer: ICP20100 & BMP388
- Mag: BMM150
- Accel/Gyro: BMI088/ICM-20649, ICM-42688-P, ICM-42670-P
- Mag: BMM150
- Barometer: 2x BMP388
- Voltage Ratings:
- Max input voltage: 6V
- USB Power Input: 4.75~5.25V
- Servo Rail Input: 0~36V
- Current Ratings: Telem1 output current limiter: 1.5A All other port combined output current limiter: 1.5A
Buying in bulk?
Get volume pricing, GST invoicing and stock availability for larger quantities of this item.
Advanced modular flight controller features triple redundancy for maximum reliability, integrating three ICM-45686 IMU sensors with BalancedGyro technology and two barometer sensors for enhanced precision. Powered by a high-performance STM32H753 processor with a clock speed of up to 480 MHz, it ensures robust processing capabilities. The modular design separates the IMU, FMU, and Base system, connected via a 100-pin and a 50-pin Pixhawk Autopilot Bus connector. With isolated sensor domains and a new vibration isolation material, this controller offers optimal stability and performance. The Ethernet interface allows for high-speed mission computer integration. Features: Triple Redundancy: Three ICM-45686 IMU sensors and two barometer sensors for enhanced precision and reliability. High-Performance Processor: STM32H753 processor with a clock speed up to 480 MHz ensures robust processing capabilities. Modular Design: Separates IMU, FMU, and Base system with Pixhawk Autopilot Bus connectors for flexible integration. Isolated Sensor Domains: Completely isolated sensor domains with separate buses and power control for maximum reliability. Advanced Vibration Isolation: Durable vibration isolation material with higher spectrum resonance frequency for optimal stability. Specifications: Processors & Sensors: FMU Processor: STM32H753 32 Bit Arm Cortex-M7, 480MHz, 2MB flash memory, 1MB RAM IO Processor: STM32F103 32 Bit Arm Cortex-M3, 72MHz, 64KB SRAM Accel/Gyro: 3x ICM-45686 (with BalancedGyro Technology) Barometer: ICP20100 & BMP388 Mag: BMM150 Accel/Gyro: BMI088/ICM-20649, ICM-42688-P, ICM-42670-P Mag: BMM150 Barometer: 2x BMP388 Electrical Data: Voltage Ratings: Max input voltage: 6V USB Power Input: 4.75~5.25V Servo Rail Input: 0~36V Current Ratings: Telem1 output current limiter: 1.5A All other port combined output current limiter: 1.5A Package Includes: 1 x Pixhawk 6X Flight Controller Module 1 x Pixhawk Standard Base 2 x PM02D HV Power Module Cable Set 1 x M10 GPS
You may also need
Holybro Pixhawk 6X Standard Set with M10 GPS